
Cheng DENG (Daven)
Bayes Centre, CSE
University of Edinburgh
Module Lead, PLIN0072
Linguistics, UCL
About Me
I work on efficient large language models, and on extending them into efficient physical AI. My research covers hardware-aware model architecture, scaling laws, efficient attention and inference, and long-context agent systems, and applies them to VLA models and embodied agents that act on robots and vehicles. Before that, my work was in natural language processing and foundation-model training, including the first generation of geoscience LLMs.
A central question across my work is how to build capable AI systems under real constraints on compute, memory, latency, energy, and interaction: from language models running on edge devices to embodied agents acting on robots and vehicles.
Currently, I am a Research Fellow at the Bayes Centre, University of Edinburgh, working in collaboration with Prof. Luo Mai, Prof. Jeff Pan, and Prof. Jun Wang. I also serve as a Visiting Research Fellow at Li Auto, and hold a lecturer-grade teaching appointment in the Department of Linguistics at UCL, where I am the module lead for Advanced Computational Linguistics (PLIN0072) in 2026–2027, responsible for its design, delivery, and assessment. Prior to joining the University of Edinburgh, I was a Research Assistant at the Hong Kong University of Science and Technology (Guangzhou), where I worked with Prof. Lei Chen and Prof. Lionel M. Ni. I obtained my Ph.D. at Shanghai Jiao Tong University, where I was fortunate to be supervised by Prof. Weinan Zhang, Prof. Luoyi Fu, and Prof. Xinbing Wang. During my early research career, I interned with the Data Team at TikTok and worked as an Applied Scientist Intern at Amazon Shanghai AI Lab. In 2021, I was selected for the Wenjun Wu Honored Ph.D. Class.
Research
My current research is organised around three connected directions:
- Efficient LLMs & Agents. Hardware-aware model architecture, scaling laws, efficient attention and inference, and long-context agent systems for resource-constrained deployment: PLM, GTA, ContextPilot, MemoryCraft, and the hardware co-design scaling laws.
- NLP, Foundation Models & AI for Science. Pre-training, post-training, reasoning, agents, and structured knowledge for language and scientific domains.
- Efficient Physical AI & Robotics. VLA and world-action models, embodied agents, and hybrid learned/classical robot systems on edge hardware, deployed on a self-built home robot and on intelligent-vehicle platforms with Li Auto.
My long-term goal is to understand how models, agents, robot skills, and hardware should be co-designed so that increasingly capable AI can operate reliably in the physical world.
News
- [2026-11] Joined the Department of Linguistics at UCL as module lead for Advanced Computational Linguistics (PLIN0072), 2026-2027.
- [2026-10] I am honored to serve as an Area Chair for ICML 2027!
- [2026-10] Two invited talks at the University of Oxford: “From Preference to Experience: Reward-Guided Learning for Physical Intelligence” and “Trust, Memory, and Reuse: Three Safety Primitives for Agent Systems”.
- [2026-09] I am honored to serve as an Area Chair for ICLR 2027!
- [2026-09] Dancing in Fetters, our hardware co-design scaling law for on-device LLMs, is accepted by NeurIPS 2026!
- [2026-09] RooflineBench is accepted by DAI 2026!
- [2026-09] EffVLA is accepted by CoRL 2026!
- [2026-08] Invited talk on “Large Discovery Model and Geoscience” at the 3rd International Symposium on Deep Underground Science and Engineering in Glasgow!
- [2026-04] 2 papers accepted by ACL Main Conference 2026, 2 papers accepted by ICLR 2026 (incl. SpatialViz-Bench), and ContextPilot accepted by MLSys 2026!
- [2026-04] I hosted an academic workshop at the Bayes Centre, University of Edinburgh, titled “Edge AI Agent Workshop”, where I also delivered a talk on “Efficient AI Agent on the Edge”.
Selected Research Highlights
Hardware Co-Design Scaling Laws NeurIPS 2026 & PLM Preprint
Pareto-optimal scaling laws that choose architectures under latency, memory, and energy constraints (Dancing in Fetters), PLM, a 1.8B peripheral language model co-designed with edge hardware, and RooflineBench for benchmarking on-device LLMs.
Scaling LawsPLMCodeRooflineBench🤗 13k+ downloadsDAI 2026
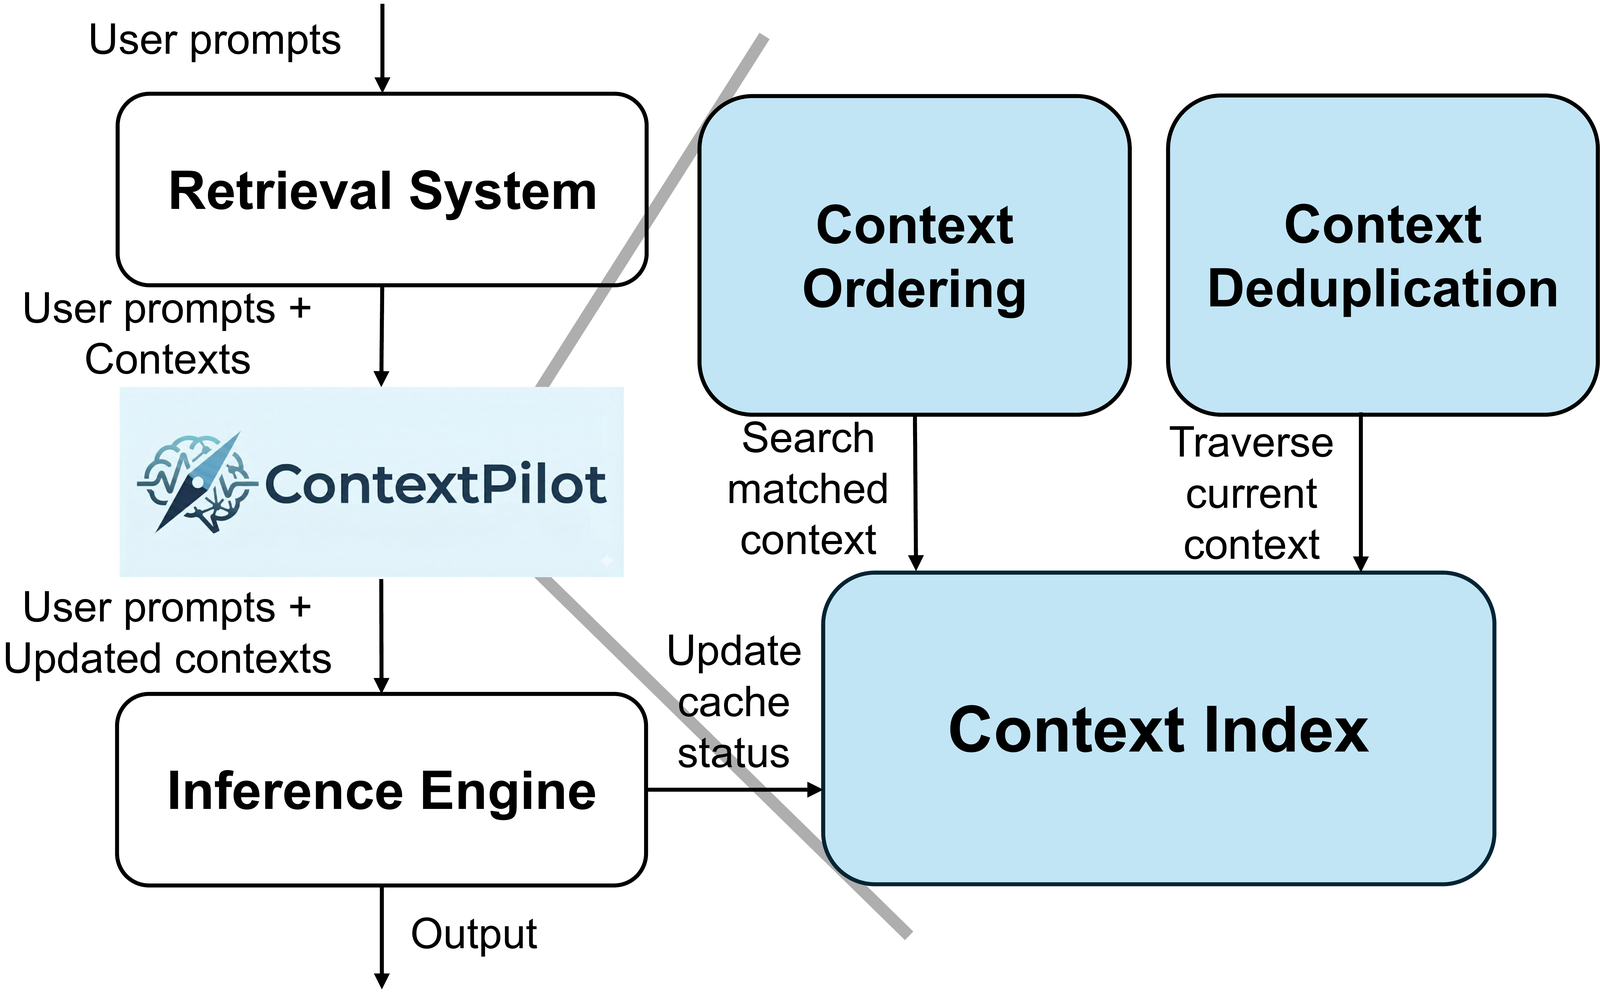
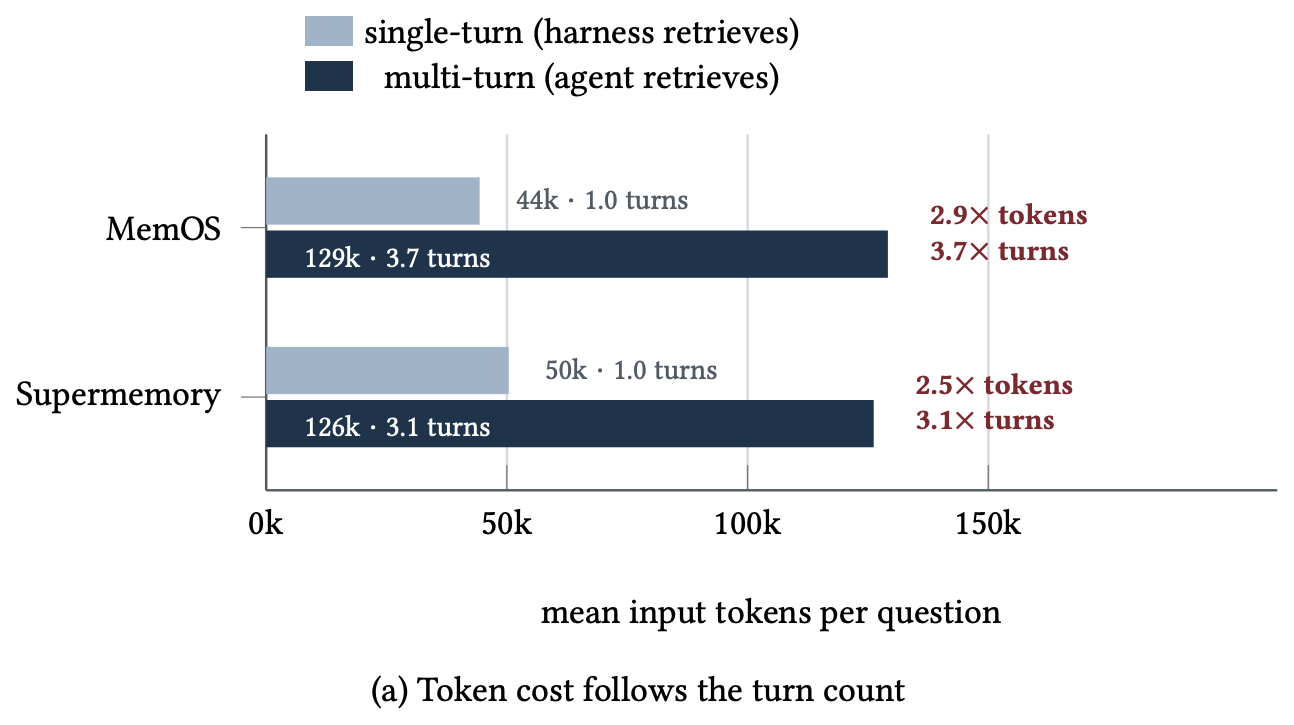
ContextPilot MLSys 2026 & MemoryCraft Under revision
Long-context agents, from inference to memory: ContextPilot cuts prefill cost through context reuse, ordering, and deduplication; MemoryCraft is a controlled platform for evaluating agent memory systems jointly with their retrieval regimes, backbones, and token cost.
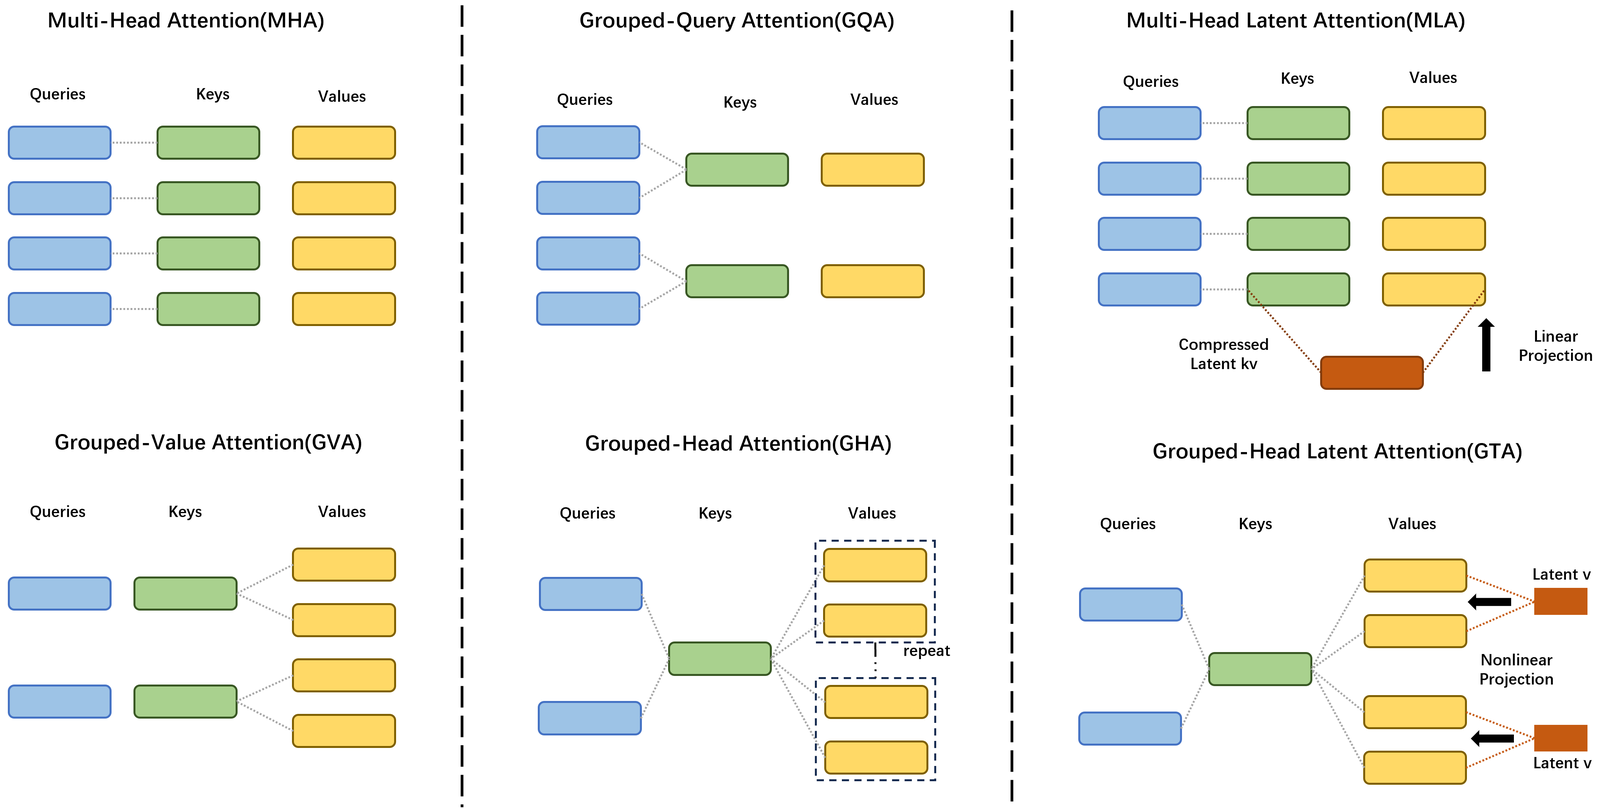
GTA: Efficient Attention Preprint
Grouped-head latent attention: sharing attention maps across head groups and decoding values from a compact latent to cut attention FLOPs and KV-cache size at matched quality.
GeoGalactica / K2 / GAKG WSDM · AI4X · CIKM
First-generation LLM foundation models for science, covering data acquisition, pre-training, SFT, and RL.
GeoGalacticaK2GAKG 314 stars🤗 2.9k downloads
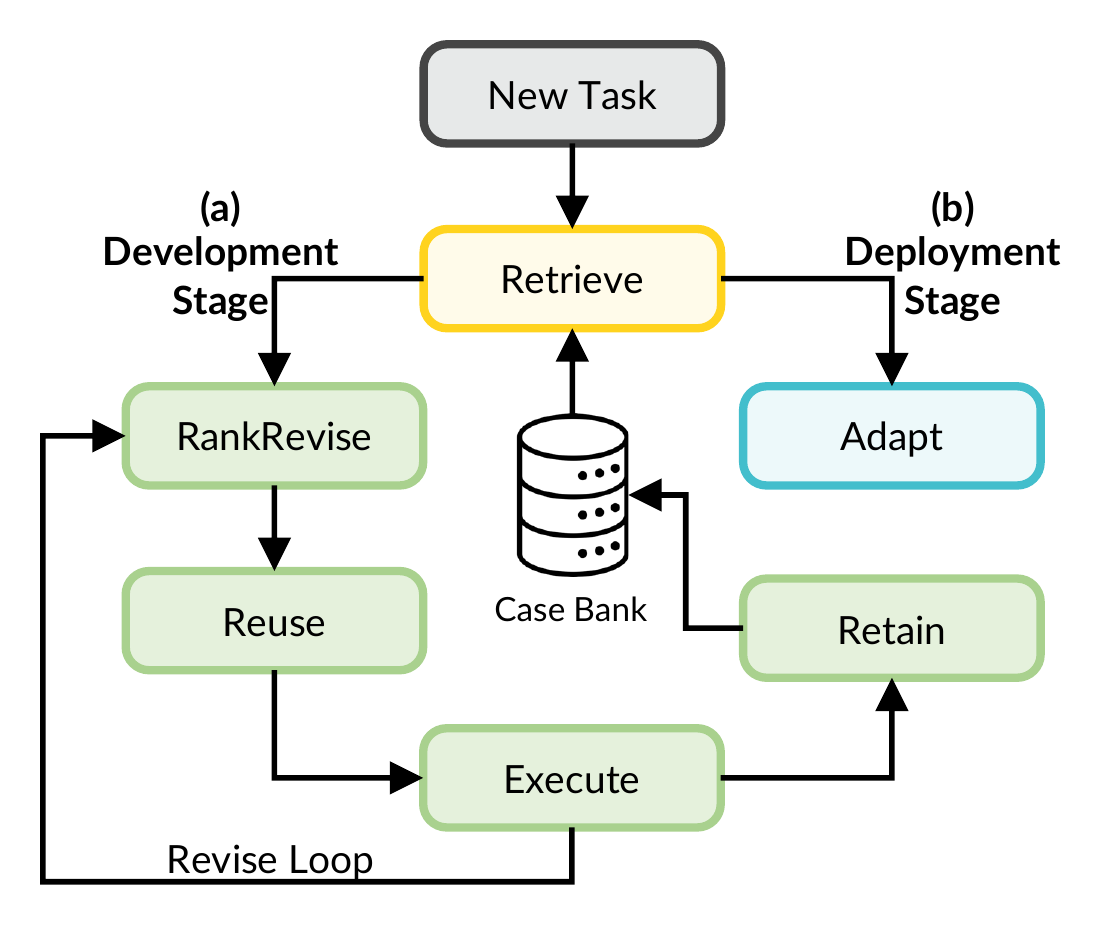
DS-Agent ICML 2024
Automated data science with LLM agents: case-based reasoning as agent skills and memory in the era of 2024.
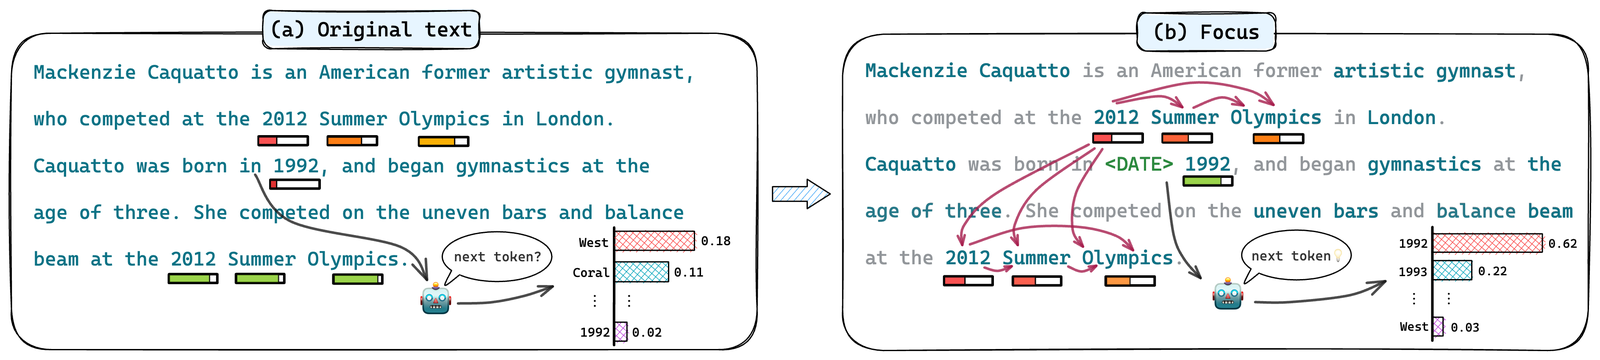
Hallucination Detection EMNLP 2023
Uncertainty-based hallucination detection for LLMs with keyword focus and history-aware propagation, improving detection without extra supervision.
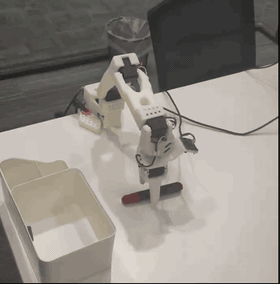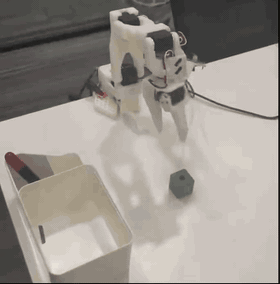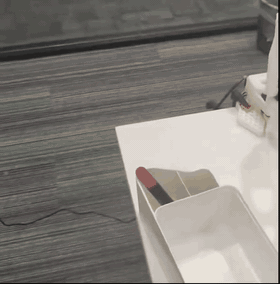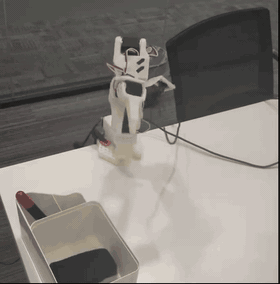
Efficient VLA CoRL 2026
A controlled, latency-aware study of modular VLA design. We identify where additional model capacity actually pays off, derive an efficient VLA recipe, and validate transfer from simulation to real robotic manipulation.
PhysicalAgent Banbu
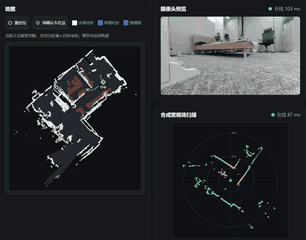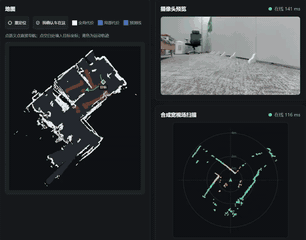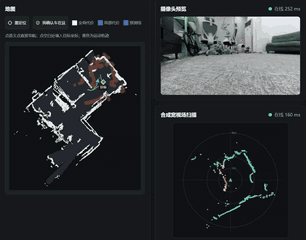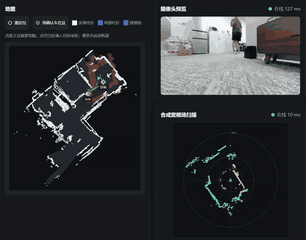
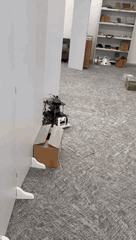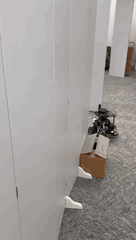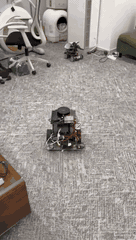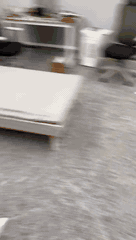
An embodied-agent testbed integrating VLA policies, SLAM/navigation, multimodal perception, and task-level agents on an untethered Jetson-powered mobile robot. We use it to study learned/classical skill composition, agent–executor feedback, and resource-aware autonomy in real environments.
banbu.aiOngoing

Efficient Embodied AI for Intelligent Vehicles and Robots Industry
VLA policies, agent–executor systems, and hardware-aware deployment for real-world vehicle and robot platforms through industry collaboration with Li Auto.
Scaling LawsEfficient VLAAdaptiveWAMLong-horizon VLAcoming soon
Platforms. PhysicalAgent mobile base: a self-built wheeled home robot I lead the team on, NVIDIA Jetson Orin on board, lidar, camera, and microphones, ROS 2 navigation, pretrained VLA plus agent loop, running untethered in a real home. Also deployed on Raspberry Pi and consumer phones (PLM), and in-vehicle edge hardware (Li Auto).
Selected Publications [Google Citation]
-
CoRL 2026 Robotics · VLA How to Build an Efficient VLA: A Design Space Study for Modular Vision-Language-Action ModelsConference on Robot Learning, 2026.
-
Under Revision Agents · Systems MemoryCraft: How Retrieval Control Reshapes Agent Memory Performance and Cost
-
Preprint Robotics · VLA π-StepNFT: Wider Space Needs Finer Steps in Online RL for Flow-based VLAs
-
NeurIPS 2026 Efficient ML Dancing in Fetters: Pareto-Optimal On-Device LLMs under Hardware ConstraintsConference on Neural Information Processing Systems, 2026.
-
MLSys 2026 Systems · Agents ContextPilot: Fast Long-Context Inference via Context ReuseInternational Conference on Machine Learning Systems, 2026.
-
DAI 2026 Efficient ML · Systems RooflineBench: A Benchmarking Framework for On-Device LLMs via Roofline AnalysisInternational Conference on Distributed Artificial Intelligence, 2026.
-
ICLR 2026 Multimodal SpatialViz-Bench: Automatically Generated Spatial Visualization Reasoning Tasks for MLLMsInternational Conference on Learning Representations, 2026.
-
-
Preprint Efficient ML PLM: Efficient Peripheral Language Models Hardware-Co-Designed for Ubiquitous Computing
-
ICML2024 Agents · NLP DS-Agent: Automated Data Science by Empowering Large Language Models with Case-Based ReasoningInternational Conference on Machine Learning
-
Conference on Empirical Methods in Natural Language Processing, 2023.
-
-
WSDM2024 NLP · AI4Science K2: A Foundation Language Model for Geoscience Knowledge Understanding and UtilizationWSDM, 2024
-
CIKM2021 AI4Science · Knowledge Graphs GAKG: A Multimodal GeoScience Academic Knowledge GraphCIKM, 2021
* Corresponding author
Teaching
- Module Lead, Advanced Computational Linguistics (PLIN0072), Department of Linguistics, University College London, 2026–2027. Lecturer-grade teaching appointment with sole responsibility for the lectures, materials, and assessment of a graduate module.
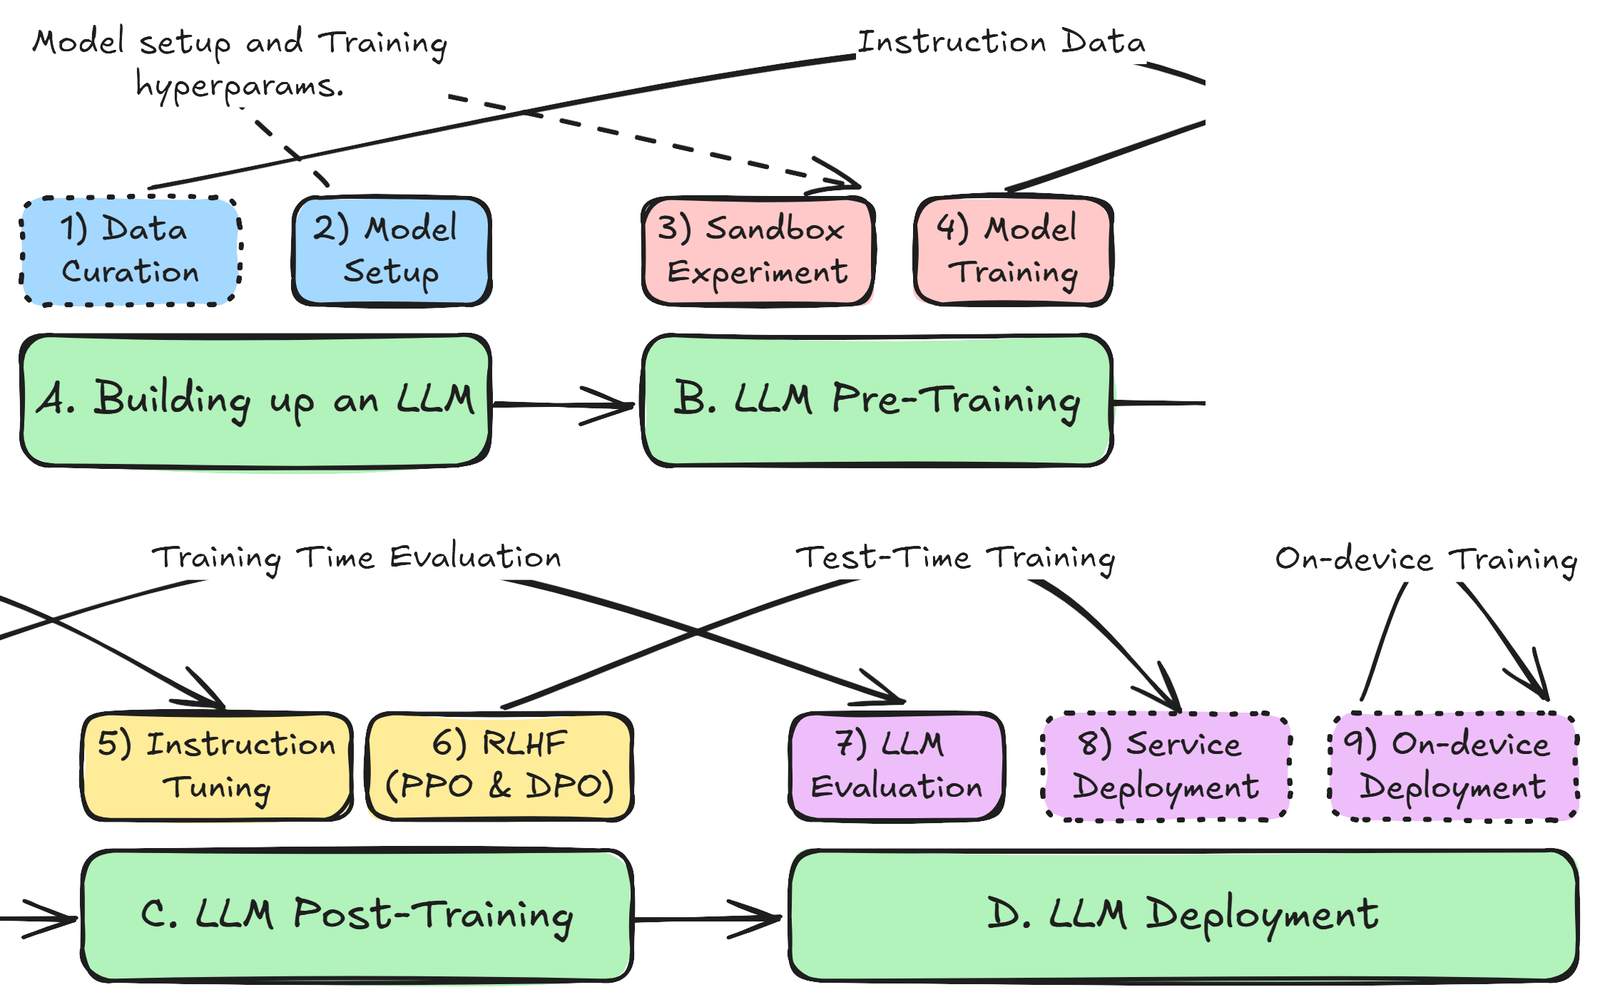
Hands-on LLM: Full-Stack Training Tutorial · RLChina 2024
An end-to-end, runnable course on training a large language model: data curation, model setup, pre-training, post-training, and deployment, with complete scripts and notebooks.
GitHub 41 starsApache-2.0
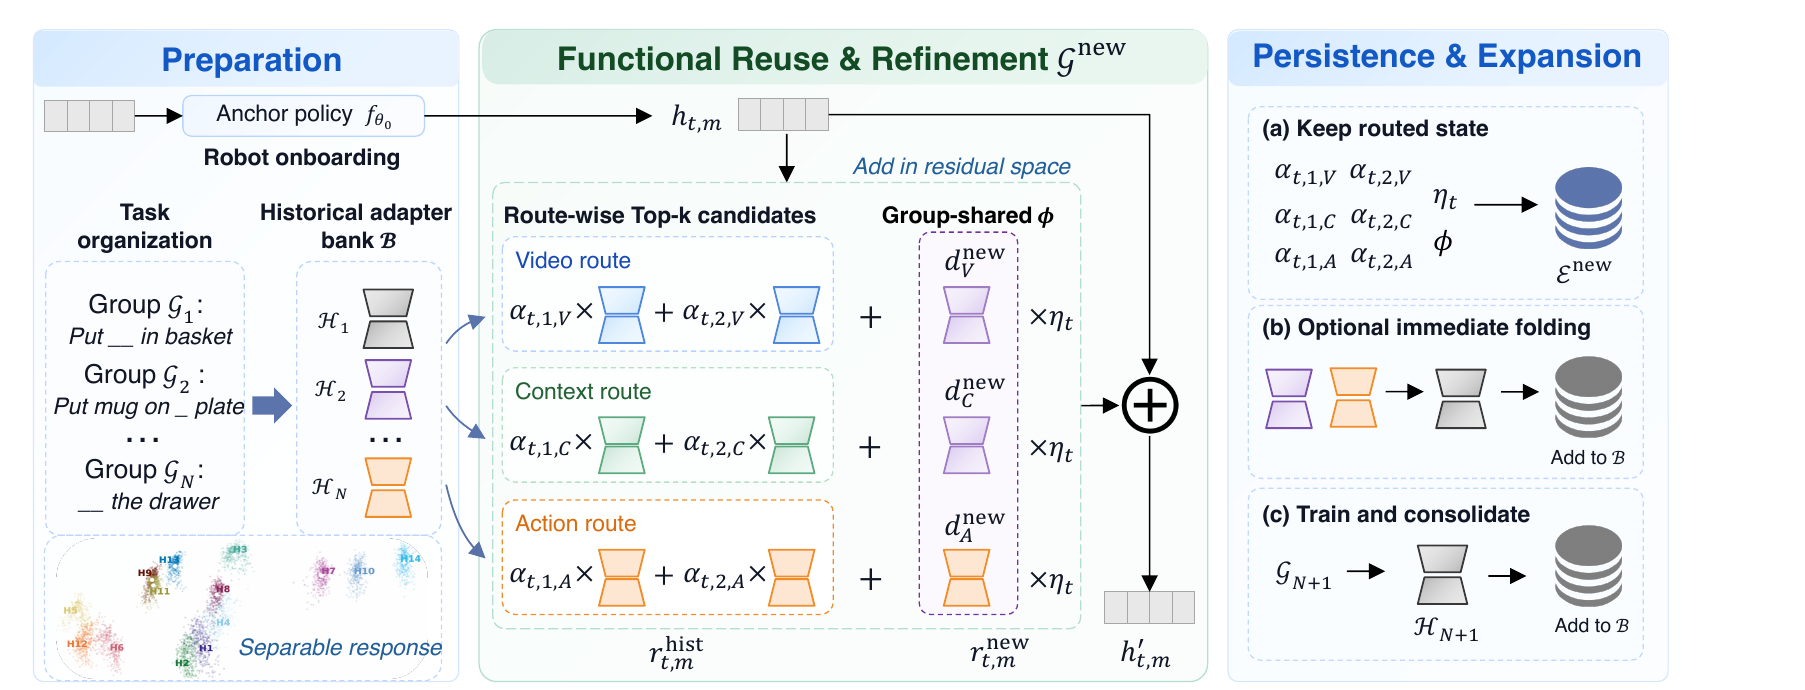
From Preference to Experience: Reward-Guided Learning for Physical Intelligence Invited talk · Oxford
An executable talk: how preference and reward signals post-train VLA policies, why flow-based policies need finer steps in online RL, and what transfers to real robots under hardware budgets. Oct 2026.
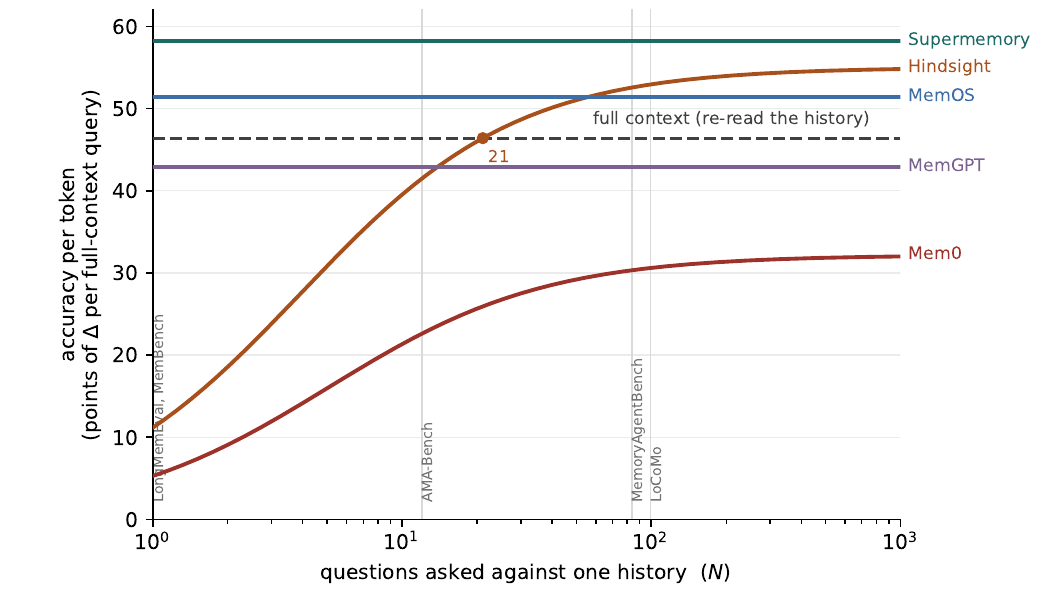
Trust, Memory, and Reuse: Three Safety Primitives for Agent Systems Invited talk · Oxford
An executable talk on three primitives that make agent failures visible and controllable: trust in inputs and tools, memory evaluated with its retrieval regime, and reuse of context without reuse of errors. Oct 2026.
- Mobile Networks (EE447), Shanghai Jiao Tong University.
- Program Design (C++), Shanghai Jiao Tong University.
- IEEI (B), Shanghai Jiao Tong University, 2020; and IEEI (B), 2021, 2022, 2023.
- Data Science (CS245-2), Shanghai Jiao Tong University, including the course Kaggle competition.
Services
- Area Chair for ICML 2027 and ICLR 2027
- Conference Reviewer for ICML, ICLR, NeurIPS, AAAI, CoRL, ACL, EMNLP, AISTATS, ACM MM
- Journal Reviewer for TMLR, TKDE, TMC, FCS, IJGIS, SWJ
- Lead Organizer, Edge AI Agent Workshop, Bayes Centre, University of Edinburgh, 2026
Funding
- Bayes Centre Strategy and Innovation Fellowship, University of Edinburgh, 2025
- Wenjun Wu AI Honour PhD Scholarship, Shanghai Jiao Tong University, 2021
Selected Talks [All Talks]
- Presented "From Preference to Experience: Reward-Guided Learning for Physical Intelligence" at the University of Oxford, Oxford, UK. Oct 2026
- Presented "Trust, Memory, and Reuse: Three Safety Primitives for Agent Systems" at the University of Oxford, Oxford, UK. Oct 2026
- Presented "Large Discovery Model and Geoscience" at the 3rd International Symposium on Deep Underground Science and Engineering, Glasgow, UK. Aug 2026
- Presented "Efficient AI Agent on the Edge" at the Edge AI Agent Workshop, Bayes Centre, University of Edinburgh (workshop host and organizer). Apr 2026
- Attended the NiklasOPF Podcast, sharing "PLM" and "Hardware co-Design Scaling Law". Feb 2026
- Presented "Efficient LLM on the Edge" at the Cardiff NLP Group seminar in Cardiff University. Feb 2026
- Presented "Efficient Physical AI and Beyond" at the Li Auto AI Sharing seminar. Dec 2025
- Organized and presented a talk on "Advanced Techniques for LLM" and delivered a tutorial on "Full Stack Practice of LLM Training" at RLChina 24, Guangzhou, China. Tutorial materials are available on GitHub. Oct 2024
- Delivered a TED Talk titled "Thinking Outside the Code" at the TEDxNYUShanghai Salon (Theme: Going Meta). Feb 2024
Powered by Jekyll and Minimal Light theme.